 Fragen

0
Beantwortet
Robot IK: Holding the rotation of TCP between targets
Andreas vor 2 Jahren
in realvirtual.io Starter and Professional
•
aktualisiert von Support vor 2 Jahren •
2
Hello,
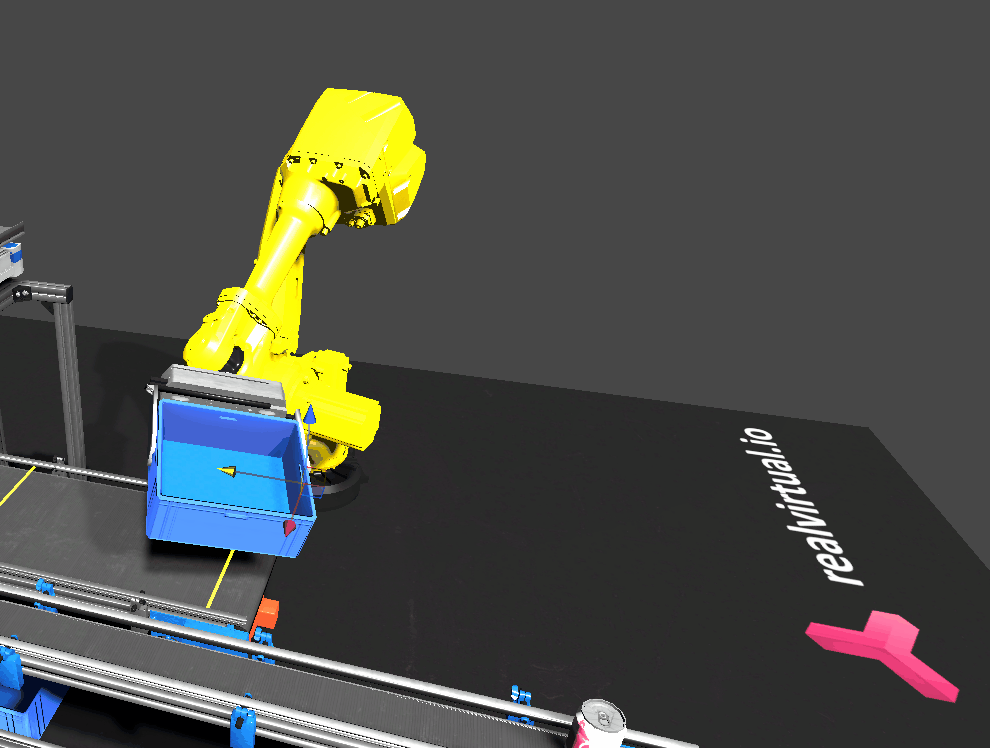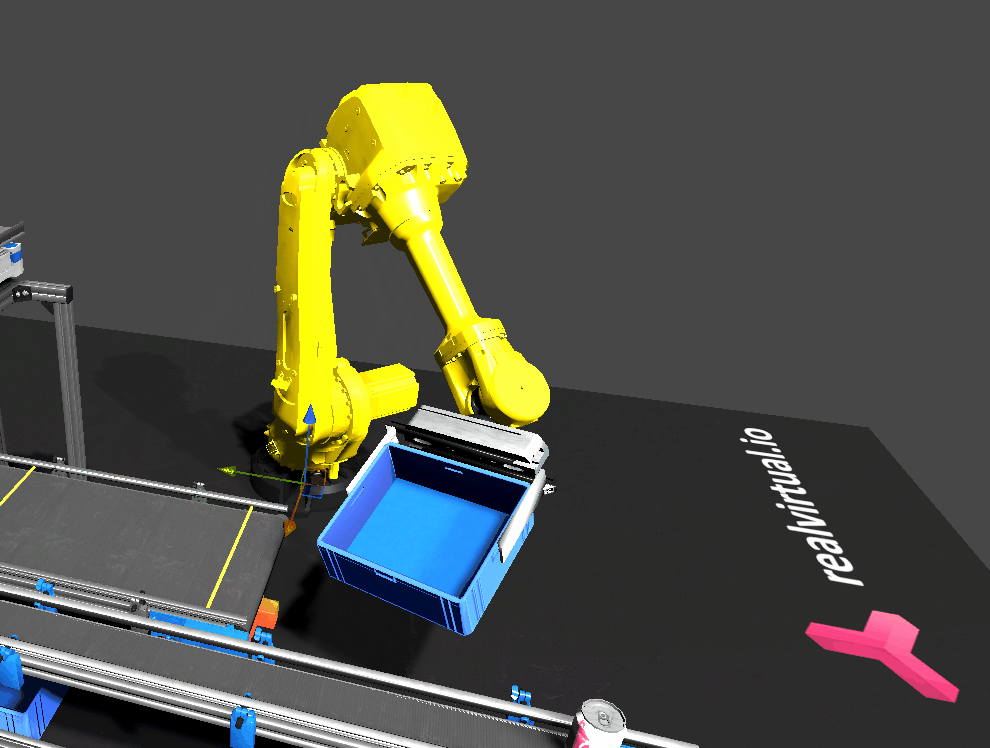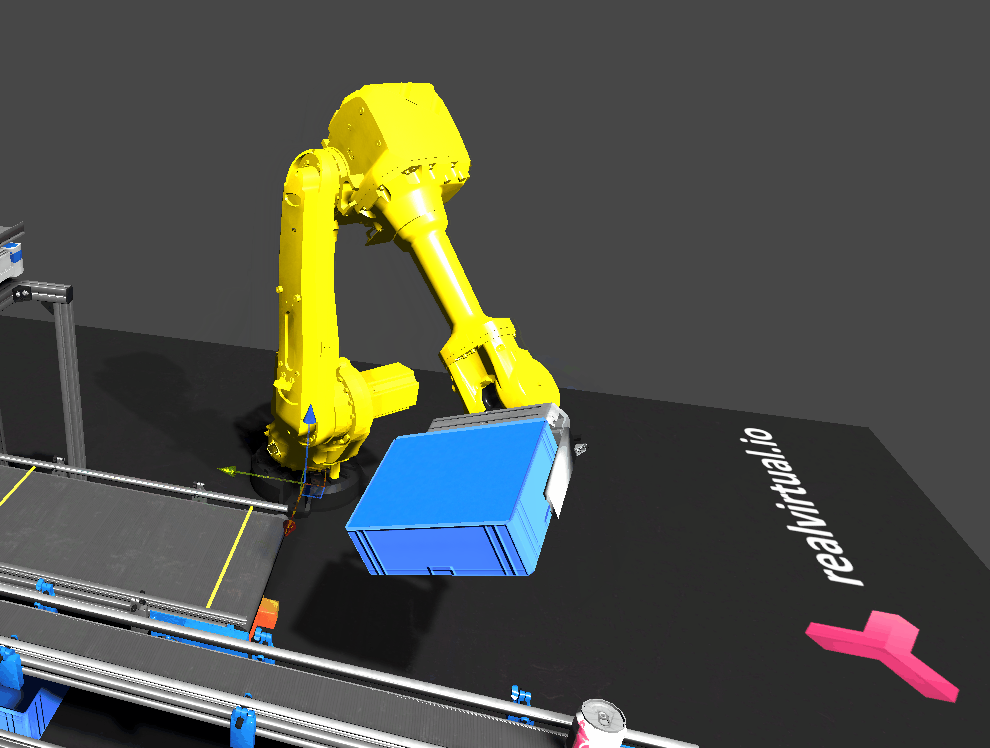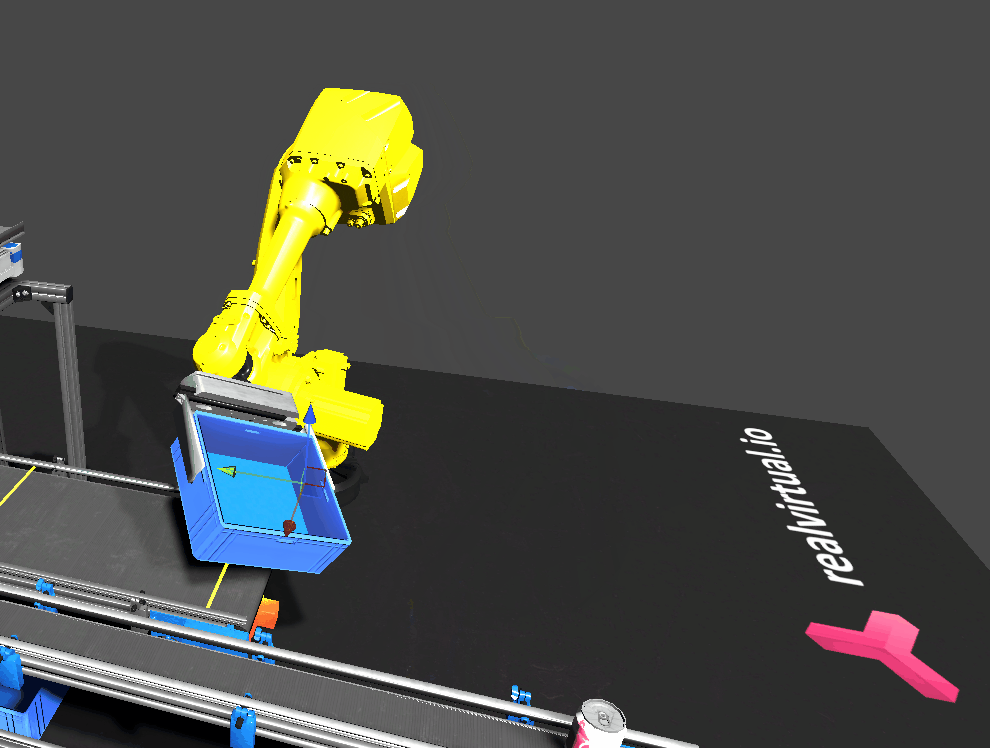
how can the robot hold the rotation of TCP between targets?
Customer support service by UserEcho
Okay, I found it.
Just need to set interpolation to target on linear.